In this four-part article series, we cover the fundamentals and new innovations related to EtherCAT. In this installment, we detail the stable versioning that keeps 2004-era EtherCAT devices compatible with EtherCAT G networks, the speed, latency, bandwidth, and throughput figures that distinguish EtherCAT from other industrial Ethernet protocols, and how it handles cyclic and acyclic communications. We also compare EtherCAT distributed clocks with the IEEE 1588 Precision Time Protocol and Time-Sensitive Networking or TSN and survey the EtherCAT components available to machine builders.
Networking + IoT
Part 1 of 4: EtherCAT then and now
In this four-part article series, we cover the fundamentals and new innovations related to EtherCAT. In this installment, we detail how EtherCAT emerged at Hannover Messe 2003 as a hybrid of Lightbus deterministic communication and Ethernet, the IEEE 802.3 Ethernet layers and frame structure at its core, and how it compares with PROFINET, EtherNet/IP, Modbus TCP, and CC-Link IE. We also explain the on-the-fly frame processing and dedicated EtherType that give EtherCAT its performance edge.
Beckhoff adds OCPP support to TwinCAT IoT portfolio
Electric vehicle technologies and charging infrastructure continue to develop. To support communication among charging networks, stations and electric vehicles, Beckhoff has expanded its TwinCAT IoT product portfolio to include the Open Charge Point Protocol (OCPP). The implementation uses the WebSocket protocol recently added to the TwinCAT IoT driver. OCPP standardizes communication between electric vehicle charging […]
TURCK previews Ethernet I/O module for roller motors

TURCK is previewing the TBEN-LLH-4RMC, a compact multiprotocol Ethernet I/O module for control and integration of conveyor roller motors in material handling and intralogistics applications. The module is scheduled for launch in the U.S. in Q2 2026. The TBEN-LLH-4RMC is intended for conveyor systems used in intralogistics, packaging and manufacturing environments where motor control, system […]
How is a serial peripheral interface (SPI) used in motion microcontrollers?
When it comes to communications in motion systems, there are a range of options depending on the specific type of use case. For instance, connecting together a series of drives and motors with controllers can be done with a number of different network protocols such as Ethernet, EtherCAT, CAN, or others. On a different scale, […]
POSITAL expands SSI options for IXARC encoders
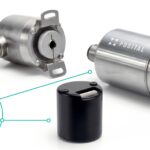
POSITAL now supports SSI communication interfaces across a broad range of IXARC absolute rotary encoders. This includes both kit (modular) encoders and industrial encoders. Both are also available in POSITAL’s new 20 mm miniature form factor. For larger encoders, SSI interfaces are offered in several mechanical configurations, including 36 mm compact models, 58 mm rugged […]
Beckhoff adds smart system diagnosis to AM8000 servomotors

As an optional predictive maintenance feature, Beckhoff Smart System Diagnosis (B/SSD) provides real-time monitoring to support predictive maintenance in motion control systems and machines. B/SSD can now be integrated into Beckhoff’s AM8000, AM8300, AM8500, AM8700 and AM8800 servomotor series. In-motor measurement of vibration, humidity, and temperature supports statistical evaluation of system health with TwinCAT Analytics […]
Beckhoff debuts ED series EtherCAT terminals with new housing
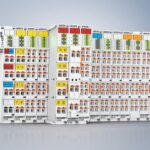
Since 2003, Beckhoff’s EtherCAT Terminals have been used for modular and scalable I/O. Beckhoff said its new ED series introduces a new housing format and adds functionality while remaining compatible with existing Beckhoff hardware. The company said the ED series also includes built-in diagnostics, consistent with other EtherCAT devices. The DIN rail-mounted ED series EtherCAT […]
Realtime systems benefit from multi-protocol motor and drive lines
Modern motion systems demand ultra-fast deterministic communication with precise multi-axis synchronization. So, engineers are turning to realtime Ethernet-based industrial protocols. Neyram Hemati, PhD Ankit Barad | Applied Motion Products Realtime motion control depends on fast, deterministic communication and precise synchronization across multiple axes. Among Ethernet-based technologies: EtherCAT delivers the highest synchronization accuracy and speed. EtherNet/IP […]
EtherCAT meets CRA Level 2 and higher-security options coming
EtherCAT meets CRA Security Level 2 requirements without modification. Extensions are being prepared for applications with higher security needs. TÜV SÜD is working with the EtherCAT Technology Group on an assessment report. Cybersecurity and cyber resilience are becoming more important as new legislation in Europe and other regions requires risk assessments and evidence of appropriate […]